The TORNADO Horizon Europe project develops technologies for robotic platforms that allow autonomous mobile robots (AMRs) to operate in complex, human-populated indoor environments. By August 2026 a first version of the overall TORNADO architecture has been established, incorporating the project’s innovative technologies into innovative systems.
The figure below shows the overall conceptual architecture. Some of the innovative project results are depicted in it. A more detailed architecture is included in the project deliverables.
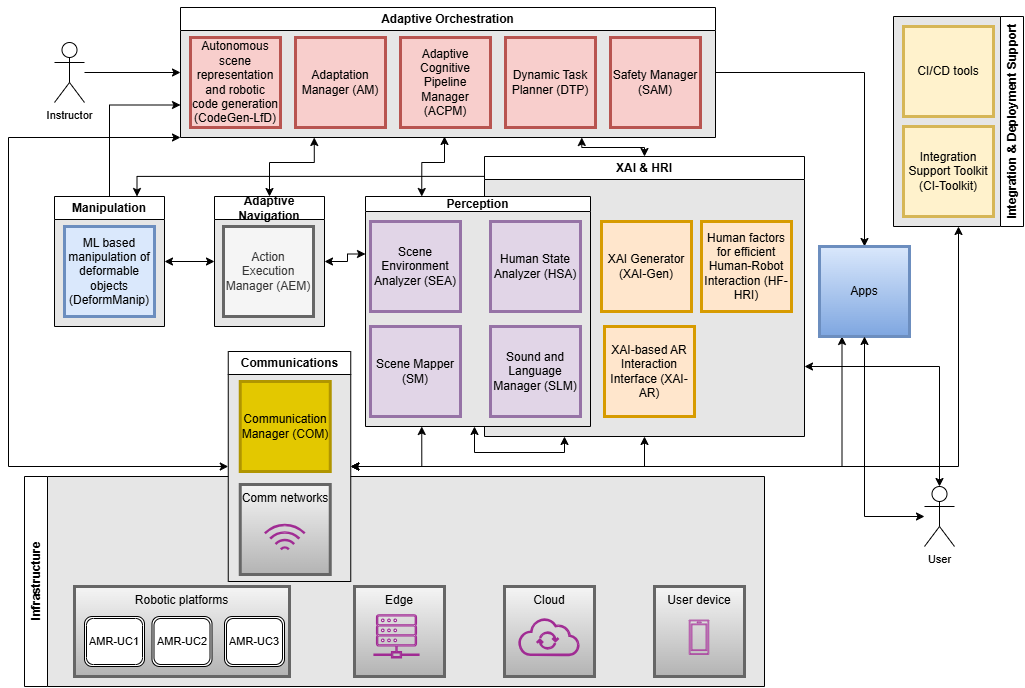
The TORNADO Infrastructure covers the robotic platforms for the 3 use cases: manufacturing, healthcare and logistics. It includes the edge and the cloud nodes where some TORNADO components may be deployed, user devices where TORNADO apps may run, as well as the communication networking among all these.
Communications offer a secure and reliable communication and computational continuum along the Infrastructure. Perception provides advanced real-time environment perception. eXplainable AI & Human-Robot Interaction (XAI & HRI) offer explainability insights and interfaces for multimodal human-robot interactions. Adaptive Navigation provides advance navigation execution, in close collaboration with the other groups. Adaptive Orchestration provides adaptive, dynamic and safe monitoring and operation of the robot modules. Manipulation provides the robotic manipulation of objects. Apps are TORNADO apps running on user devices. Integration & Deployment Support offers tools to assist in the integration and deployment of TORNADO modules.
The Instructor interacts with Adaptive Orchestration to teach new tasks or instruct adaptations. The User represents typical users in the 3 Use Cases.
The development and integration of the 3 robotic system solutions continues, with pilot testing planned next year.